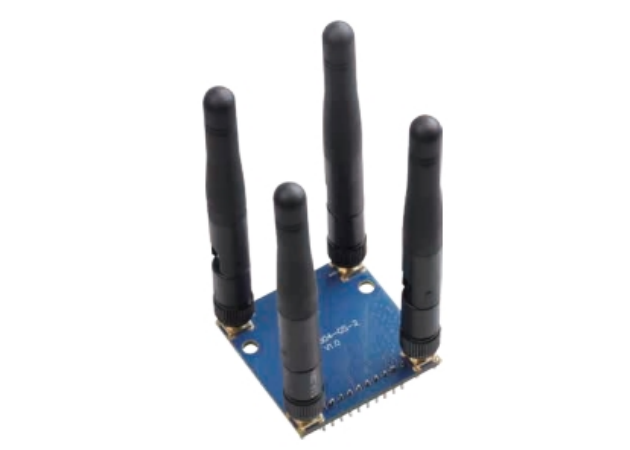
Measurements for a following controller
GC-P2304-GS-2 provides distance and angle information; the following behaviour is implemented in the host controller. The documentation lists AGV carts, camping trolleys and golf caddies as example applications. It does not make the board a complete vehicle-control or safety system.
Define the host interface before the motion test
The listed UART interface has selectable baud rates, and the module has its own supply-voltage and receive-current requirements. Request the message format, supported tag configuration and firmware revision needed by your controller. Do not assume a public SDK or a particular host protocol is included.
Distance accuracy, angle accuracy and the 30 m open-space range describe different aspects of the measurement. Specify which output the controller uses and the conditions under which the complete product needs to follow a target.
Build a representative evaluation route
- Include approach, turning and obstruction cases relevant to the host product.
- Record antenna placement, tracked-tag count and the actual measurement update behaviour.
- Log unavailable measurements and the host’s response when a tag is lost or reacquired.
- Keep measurement performance separate from the motion-control decisions made by your software.